01 / 06
Opalin
Robotics hardware engineer · founding team2026 – now
Physical AI for real-world operations. I design the arm's hardware: the mechanics, intricate flex PCBs and the sensing around them.
Read more ↓Physical AI for real-world operations. I design the arm's hardware: the mechanics, intricate flex PCBs and the sensing around them.
Read more ↓Warehouse on wheels. I worked on the actuators and power management, and on the robot's physical design.
Read more ↓I designed and manufactured miniature magnetic robots to steer to and capture blood clots in stroke thrombectomy. Patent pending.
Read more ↓Heavy-duty engines that run on ethanol. I built the on-board diagnostics in OpenECU and Simulink, to SAE J1939.
Read more ↓Autonomous baggage tractors at CVG airport. I integrated the sensors and actuators and the CAN link between the MCU and VCU.
Read more ↓A 3D-printed myoelectric arm for children. I designed the electrical system: EMG muscle sensing and the servos it drives.
Read more ↓A few souvenirs. Tap one to jump to it.
The jobs behind the machines above.
Hardware for physical AI in real-world operations. I design the robot's mechanics, intricate flex PCBs and the sensing around the arm.
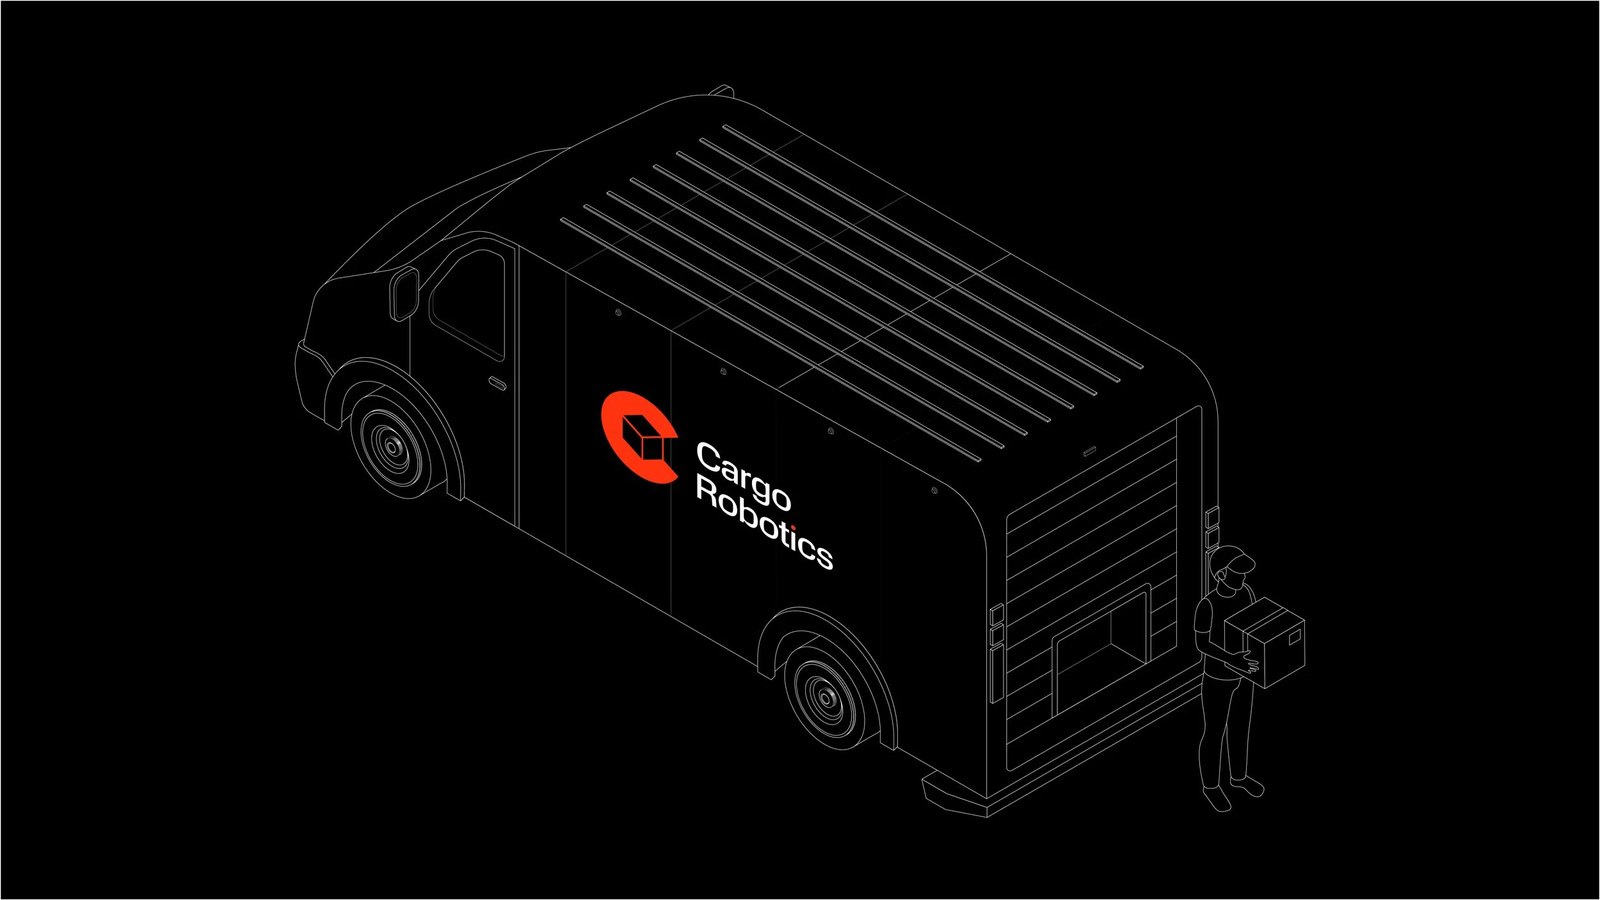
Warehouse on wheels. Joined before the Series A and worked on the actuators, power management and the robot's physical design, along with the electronics cabinet, PCBs, harnesses and CAN bus, to get it ready for customer pilots.
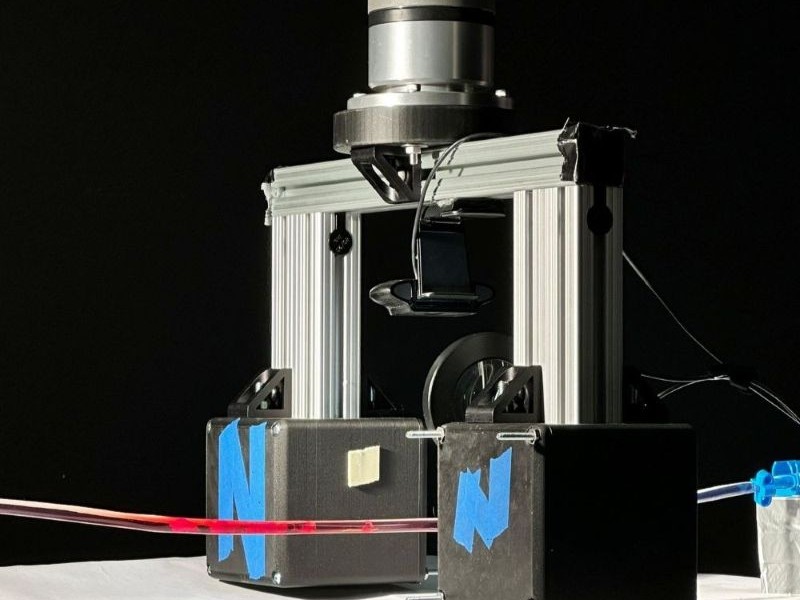
Co-invented the patent-pending M3 thrombectomy robot. Designed and manufactured miniature magnetic robots to steer to and capture blood clots, ran the FEA, and helped build the vision-based tracking.
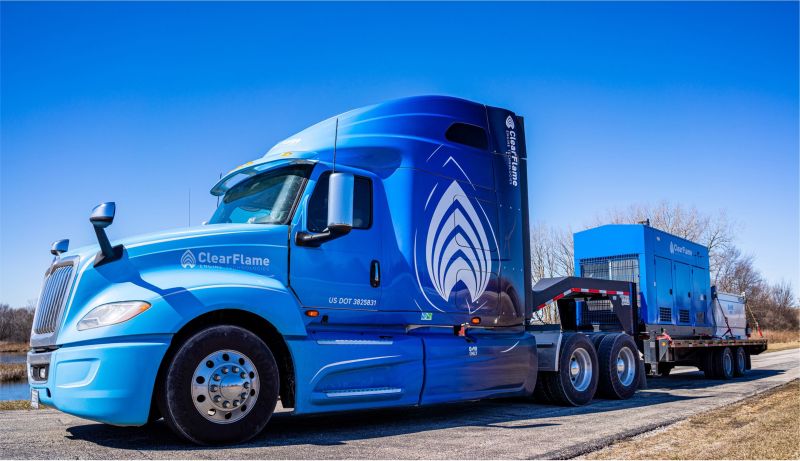
Built on-board diagnostics for heavy-duty engines that run on ethanol instead of diesel: modular Simulink libraries that monitor digital, analog and CAN signals across the engine, plus a test harness to validate them.
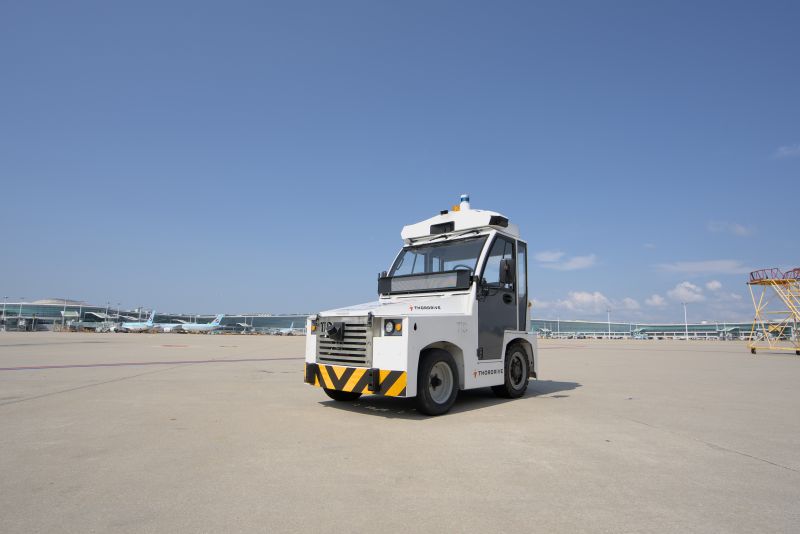
Integrated sensors and actuators on autonomous airport baggage tractors, wrote a J1939 layer carrying 60+ sensor messages between the MCU and VCU, and automated analysis of 4.5M+ lines of CAN, IMU and GNSS logs. Product video ↗
Hover a photo for a closer look.
A modular magnetic robot for stroke thrombectomy. Steered by an external magnet on a UR16e arm, its segments travel through the vessel and expand at the clot. Built at ASU's Bio-Inspired Robotics, Technology & Healthcare Lab with Mayo Clinic.
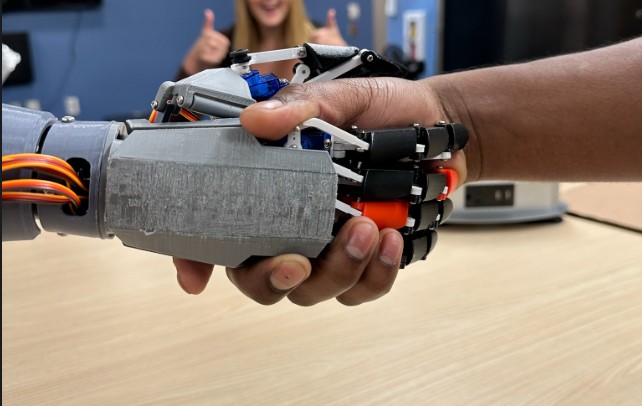
Led the electrical design of a 3D-printed myoelectric arm for children, from the muscle sensors to the servos, and co-wrote the grant applications. An EPICS at ASU project.
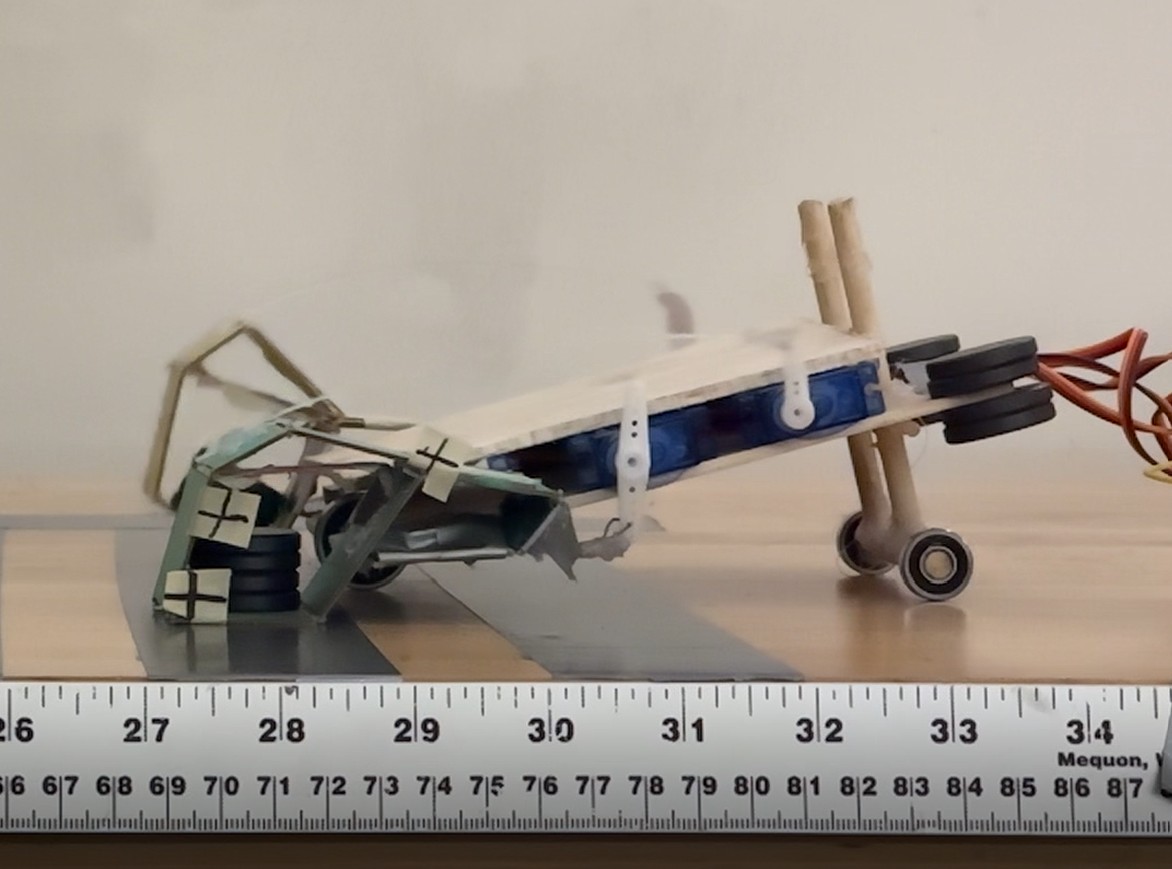
Tuned an ostrich-inspired gait in MuJoCo with soft-body physics, then built the robot with an ESP32 and servos and compared its stride and stability with the sim. Group project.
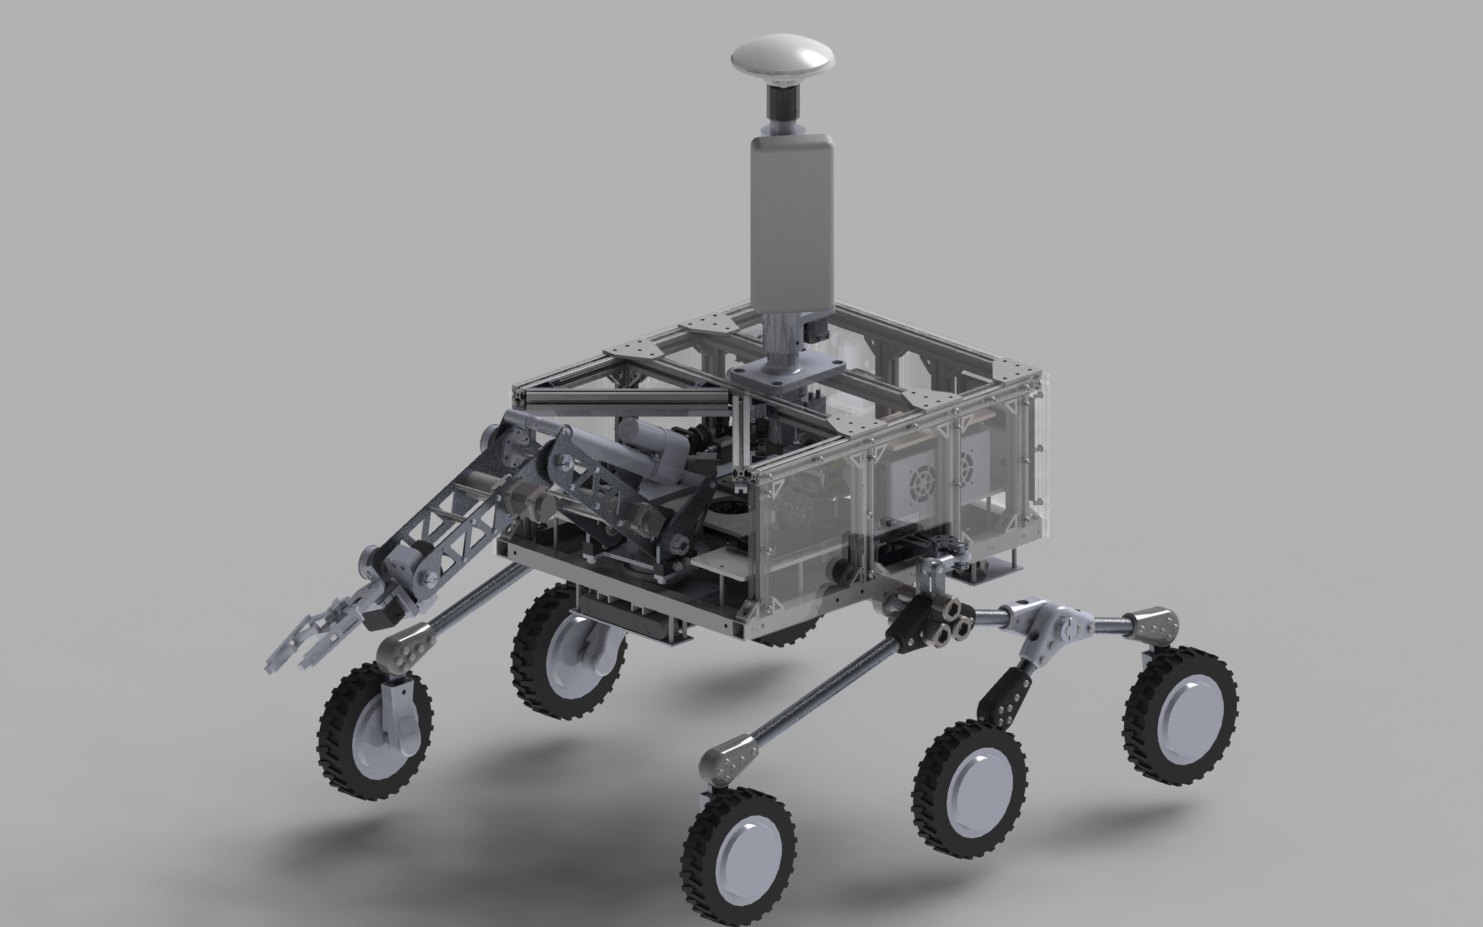
Led the robotic arm on the club's rover for the University Rover Challenge (URC), and helped run the 50-member club on the management team.
Where the habits came from.
| 2nd | Devils Invent · Honeywell | Voice-assistant co-pilot |
| 2nd | Devils Invent · Honeywell | QA + inventory automation |
| 2nd | HacksForHumanity | LLM community resolution app |
| 3rd | Devils Invent · LANL | Gesture-controlled robot arm |
| 3rd | Devils Invent · Honeywell | Multi-robot part delivery |
| 3rd | HabitHacks | Robotic desk assistant |
From ASU's Bio-Inspired Robotics, Technology & Healthcare Lab.